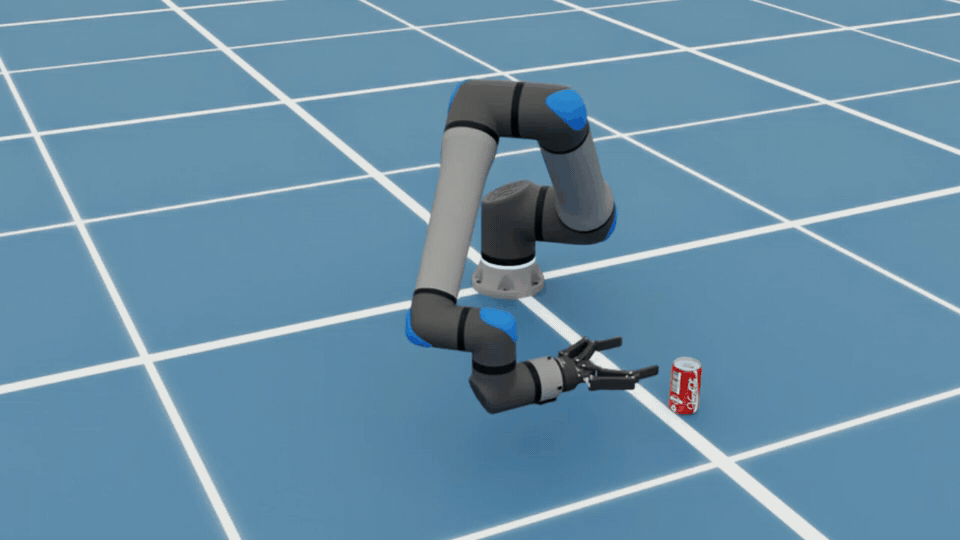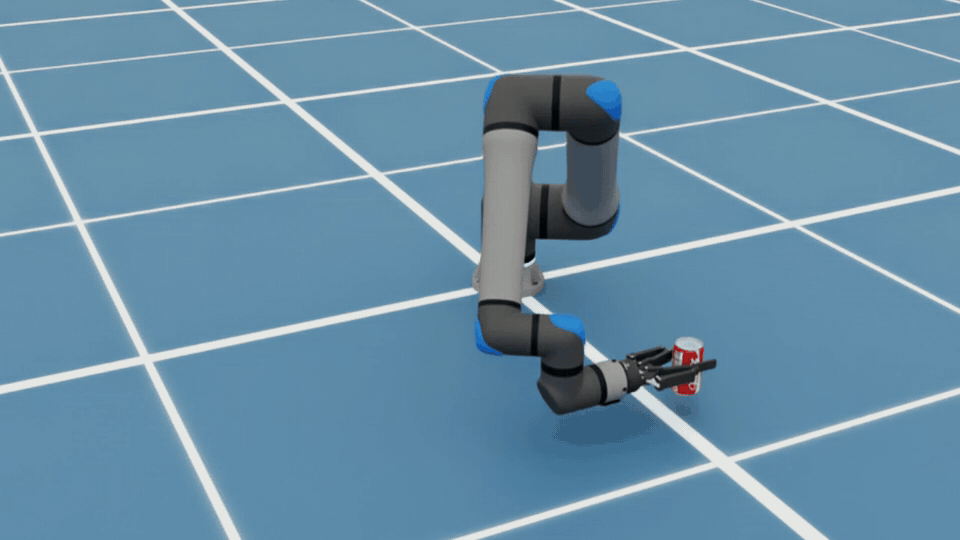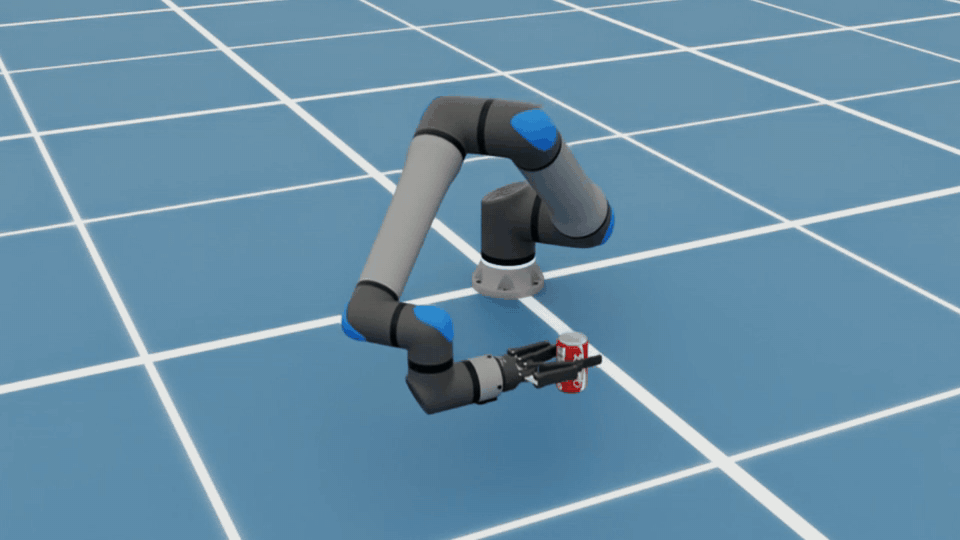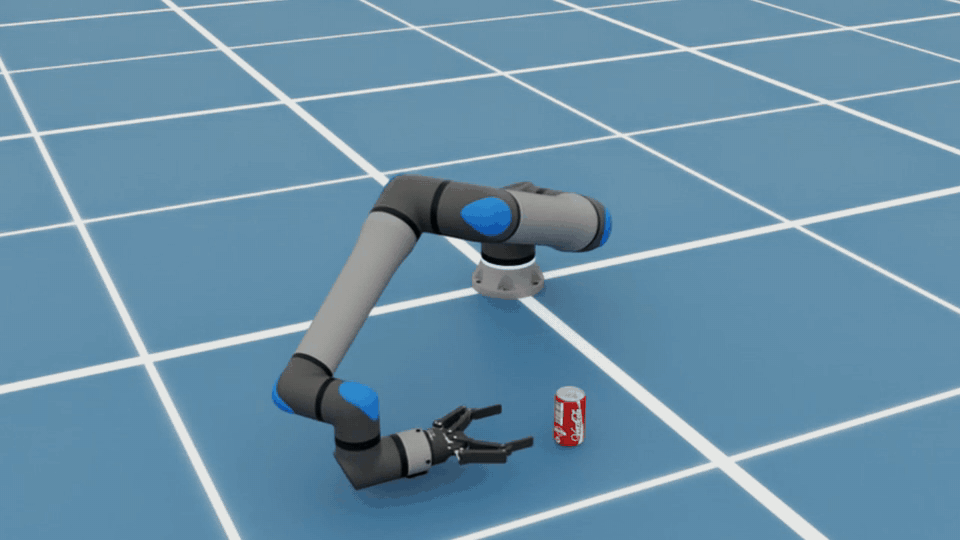
Back to Articles Build a Robot Pick-and-Place Simulation with SimReady Assets Enterprise + Article Published November 13, 2026 Upvote 5 Dillon Bailey dillonb-nv nvidia Pomi Lee pomilee nvidia Rishabh Chadha rchadha-nv nvidia This walkthrough showcases a beverage can pick-and-place task that uses the UR17G arm, Robotiq 2F-140 gripper, and beverage can to compose a scene in Isaac Sim, check their behavior, and run a pick-and-place example with agent-generated controls. For robotics workflows, SimReady means an OpenUSD asset has been prepared with the properties needed for a defined simulation use case, such as collisions, mass, joints, and joint drives. SimReady Central, an open asset library on Hugging Face, lets you reuse robot and object assets…
Build a Robot Pick-and-Place Simulation with SimReady Assets
Advertisement